Qinlei Xie
About Me
I am Qinlei Xie (谢钦磊), an undergraduate at Dalian University of Technology, majoring in Big Data Management and Application, with an expected graduation in June 2028. I previously conducted research at Tsinghua University under the guidance of Zheng Lu.
I am interested in learning world representations that improve how robots act. My broader interests include the action capabilities of vision-language-action models (VLAs), joint world-action representations, and video world models for robot learning. I am also interested in incorporating tactile and force feedback into manipulation policies to capture contact information that vision alone cannot reliably observe.
Research Interests
- Generalizable robot policies: action representations, continuous action generation, and policy learning across objects, scenes, and tasks.
- World-action representations: integrating latent dynamics and world representations with action prediction for closed-loop control.
- Video world models: action-conditioned video prediction and its use in policy learning, planning, and interaction data generation.
| Scope | Focus |
|---|---|
| Long-term goal | Build generalizable robot manipulation policies by jointly learning world representations and actions, incorporating visual, tactile, and force feedback. |
| Current work | Study action-conditioned residual latent dynamics in visual JEPA world models: predict state changes rather than full future representations, and evaluate their effect on planning and multi-step rollouts. |
| Current exploration | Explore the capabilities and limitations of LLMs in robotics, and how to improve latency and real-time responsiveness, fine-grained manipulation, and dexterous hand control. |
I welcome discussions, suggestions, and guidance on these questions.
News
- [2026] Towards Spatial Supersensing in the Wild was accepted to ECCV 2026.
- [Jun. 2026] Our preprint Token Predictors Are Not Planners is available on arXiv.
- [2026] GameVerse was accepted to ICML 2026.
Publications
-
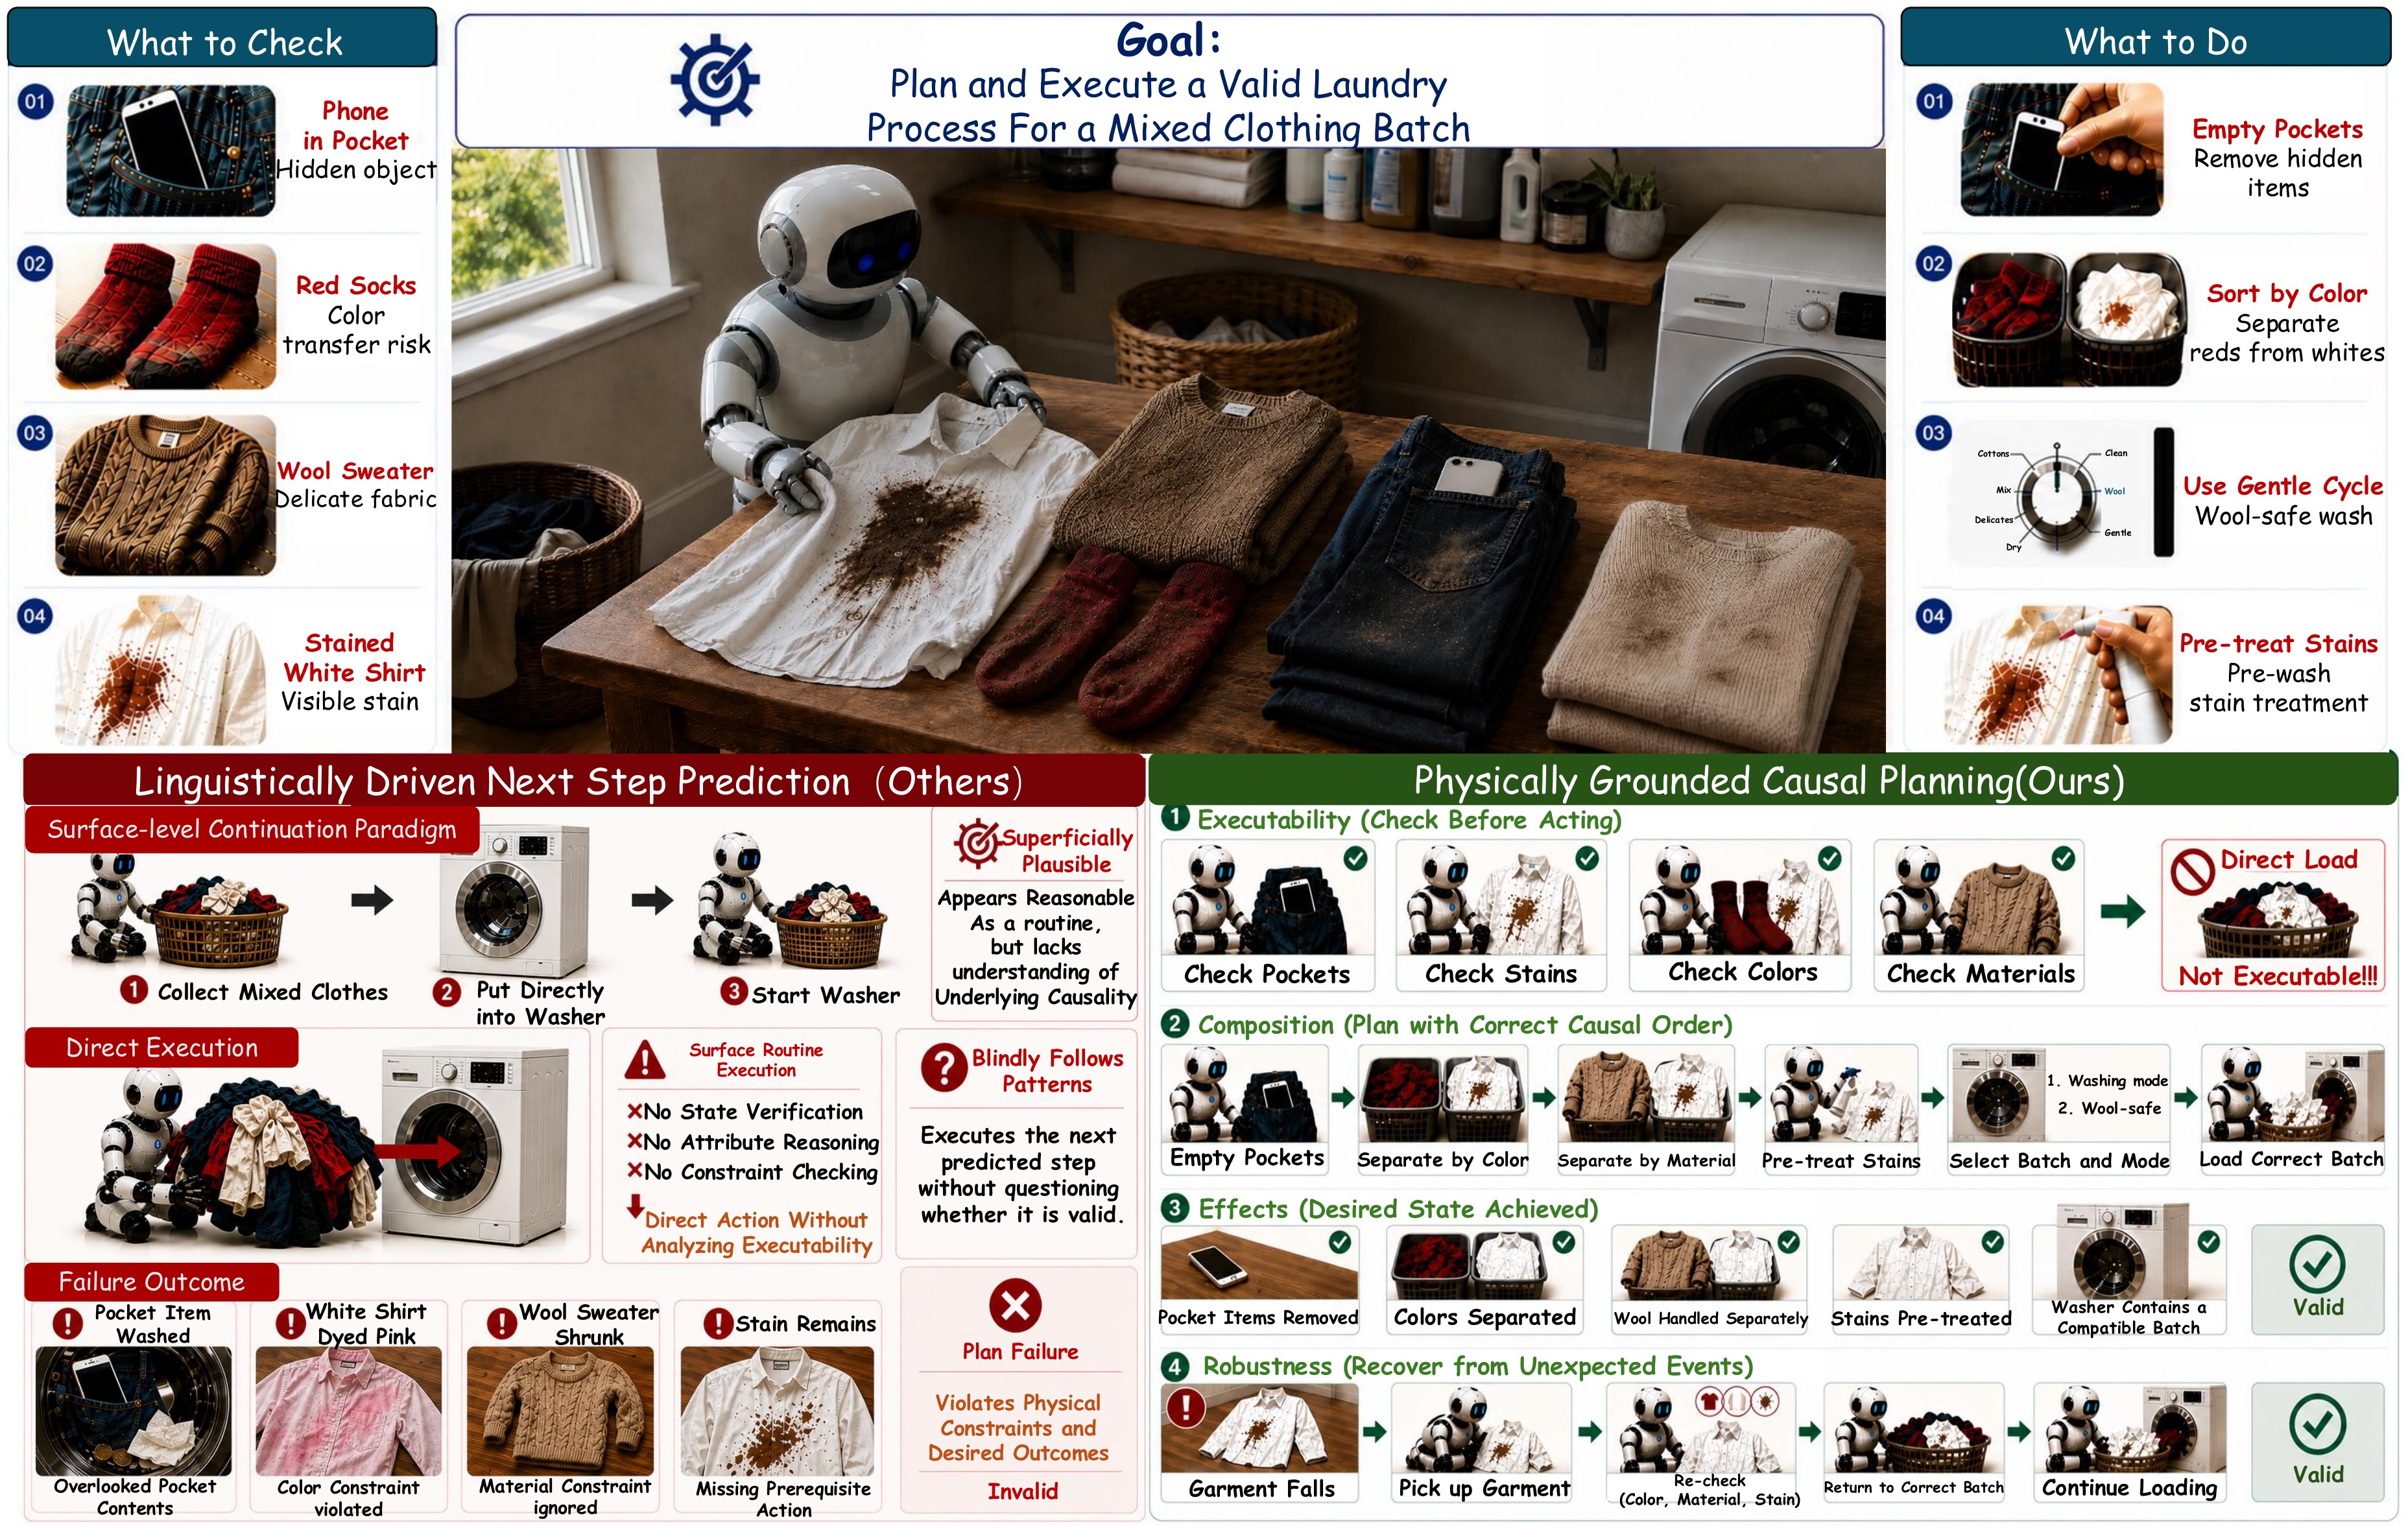 arXiv
arXiv preprint, 2026.
-
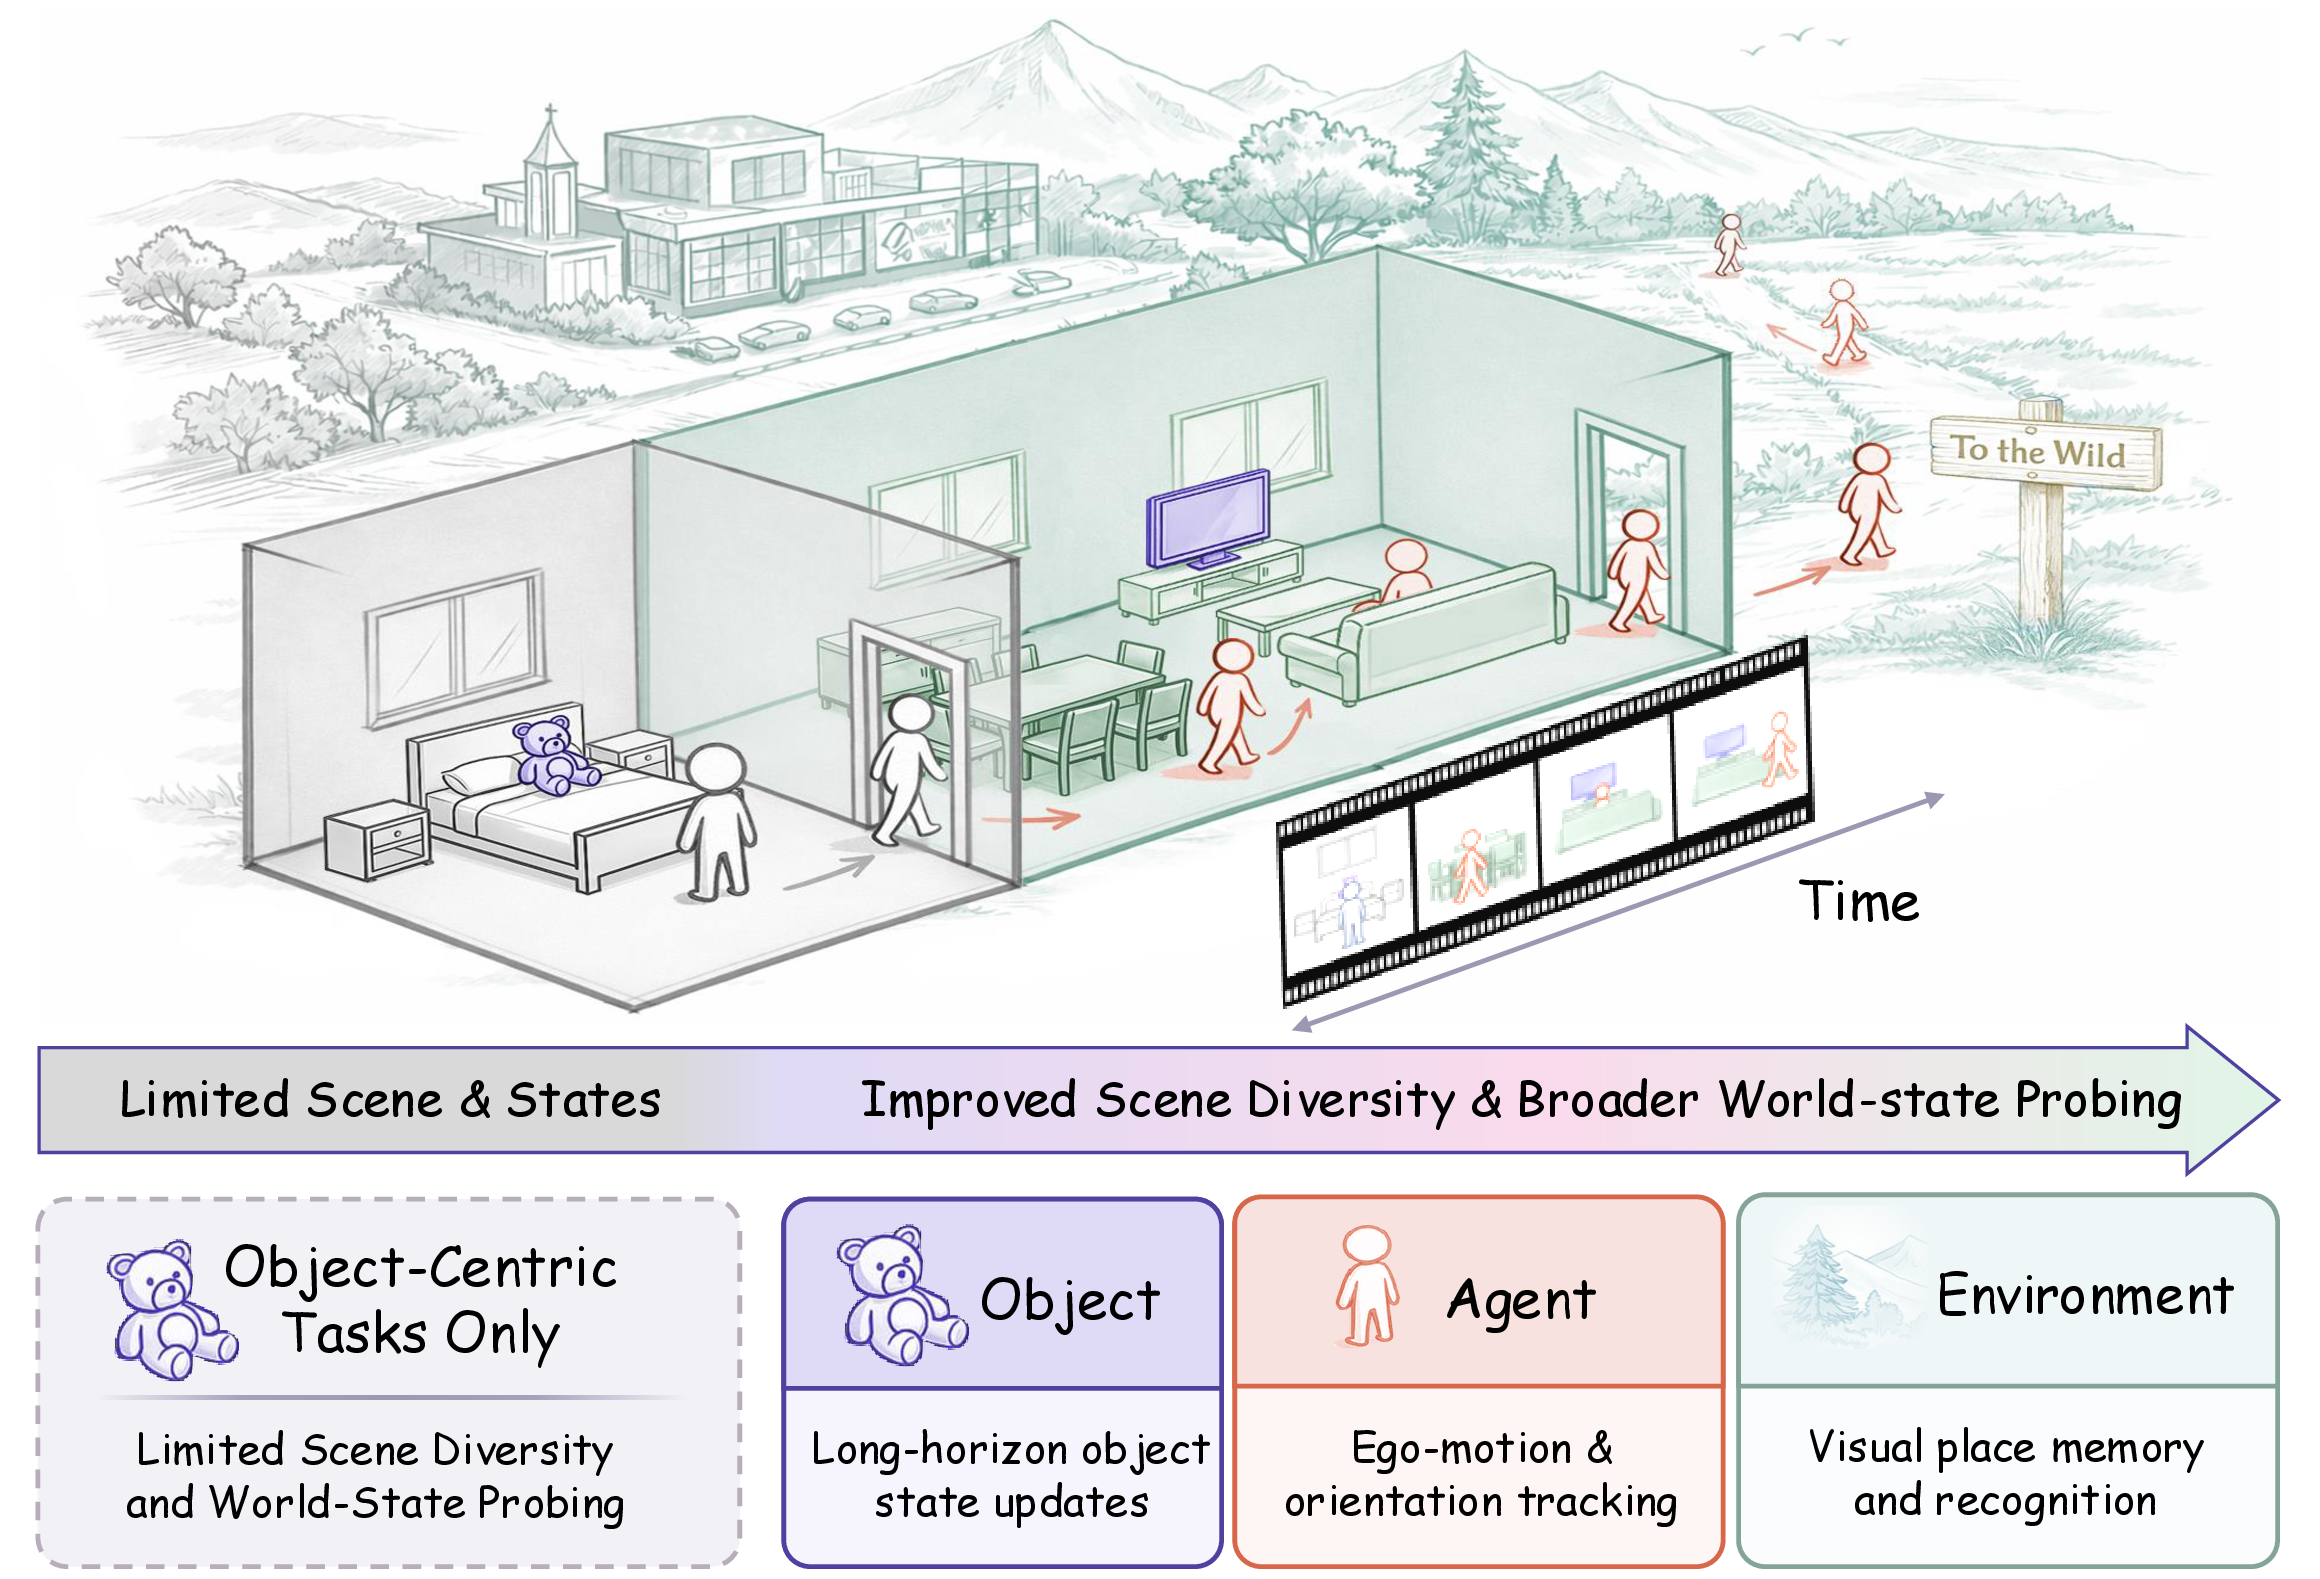 ECCV
European Conference on Computer Vision (ECCV), 2026.
-
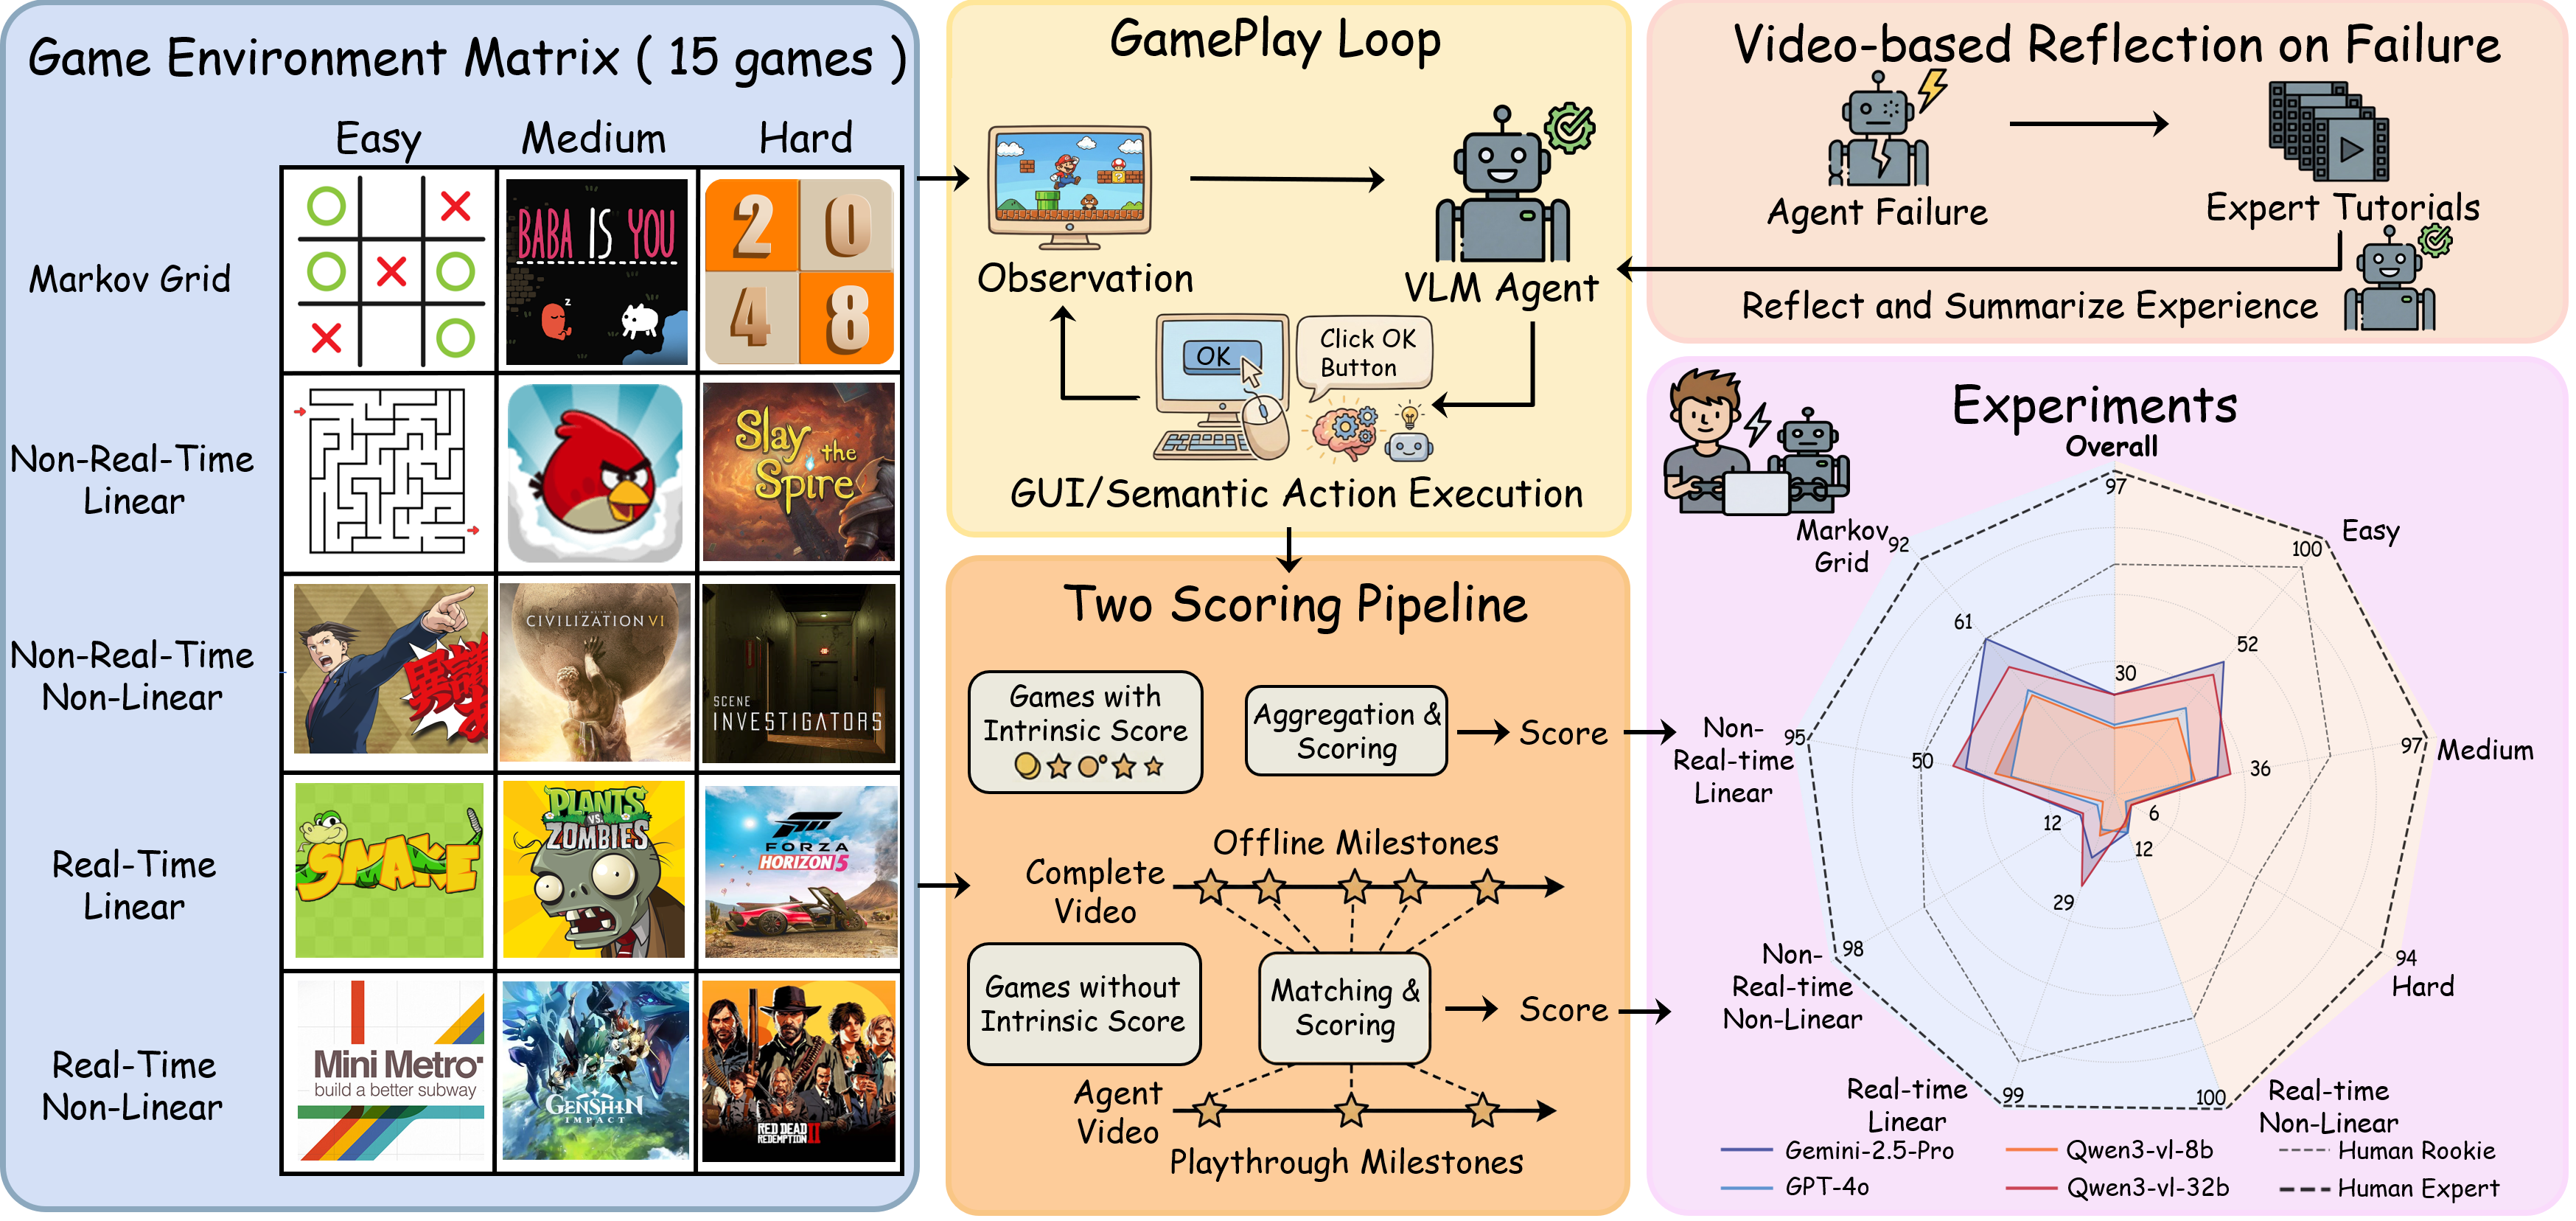 ICML
International Conference on Machine Learning (ICML), 2026.
Education
Dalian University of Technology
B.S. in Big Data Management and Application
September 2024 - June 2028 (expected)
Hobbies
- Piano: I have studied classical piano since childhood and passed the Grade 8 examination.
- Basketball: I play as a swingman and enjoy shooting and driving to the basket.
Powered by Jekyll and Minimal Light theme.